Publications
Group highlights
At the end of this page, you can find the full list of publications and patents. All papers are also available on arXiv.
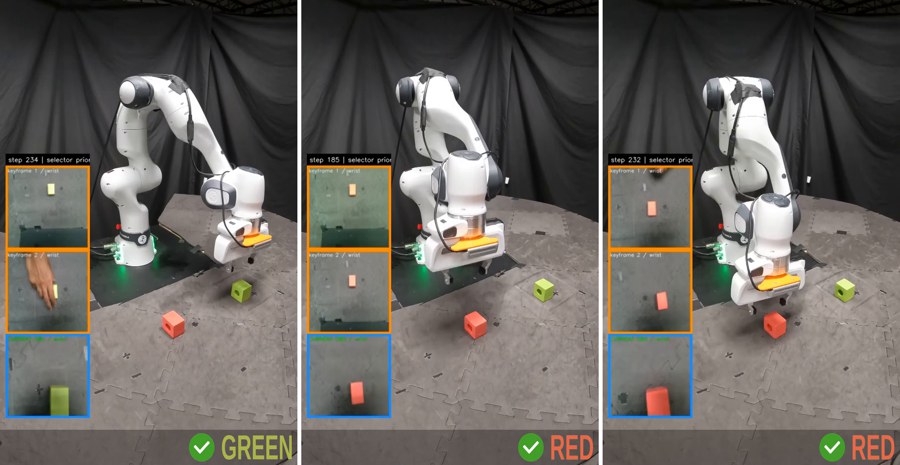
Behavior cloning in non-Markovian environments requires reasoning over long horizons, where recurrent models suffer hidden-state collapse and attention-based models are limited by context length. Keyframe Mnemonics is a self-supervised method that discovers a small set of information-critical observations (mnemonics) and conditions the policy on them, providing context retention over long horizons. It achieves 100% success on synthetic memory tasks, generalizing to horizons far beyond training, and improves success by 13.9% over the strongest baseline across 23 memory-intensive manipulation tasks.
Prabin Kumar Rath, Omkar Patil, Nakul Gopalan
2026 Conference on Neural Information Processing Systems (NeurIPS)
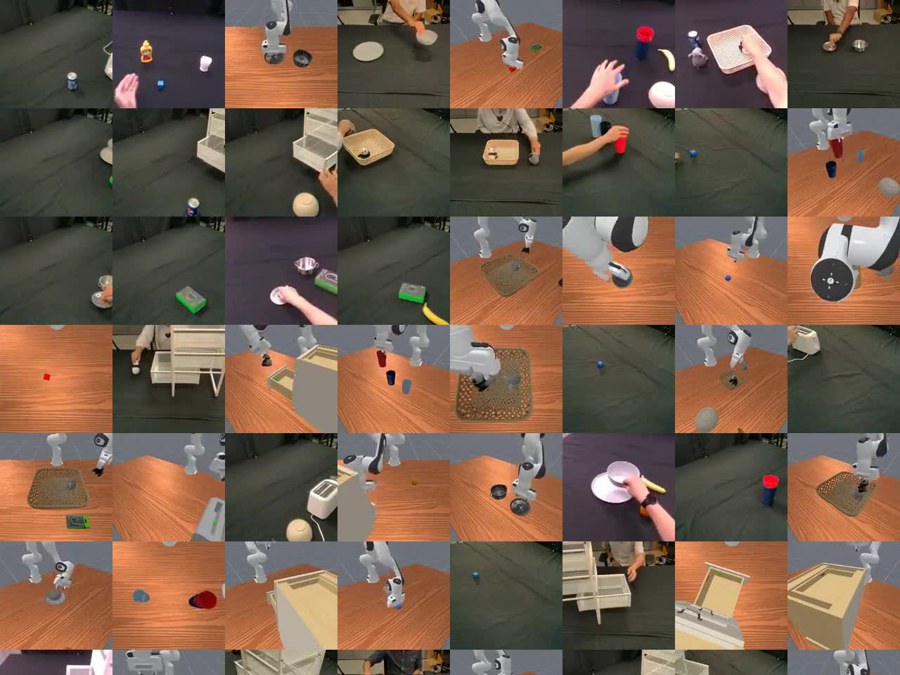
Learning from observation lets robots acquire skills from human videos, but existing methods vary widely in assumptions, hardware and setups, making progress hard to assess. RoboReel is a unified benchmark that pairs real-world human demonstration videos with simulated robot trajectories and evaluation environments across ten manipulation tasks, with four test suites covering robustness to visual distractors and long-horizon tasks. Evaluating over seven state-of-the-art algorithms, including VLA-based variants, shows that long-horizon and low-tolerance tasks remain challenging.
Weiwei Gu, Anmol Gupta, Anant Sah, Ryan Varghese, Lalitha Shreya Vanam, Prabhath Adireddi, Peter Karkus, Nakul Gopalan
2026 Conference on Robot Learning (CoRL)
Full List of publications
Self-Supervised Keyframe Discovery for Horizon-Invariant Behavior Cloning
Prabin Kumar Rath, Omkar Patil, Nakul Gopalan
2026 Conference on Neural Information Processing Systems (NeurIPS)
Monkey See, Can Monkey Do? A Benchmark for Evaluating Robot Skill Learning by Observation
Weiwei Gu, Anmol Gupta, Anant Sah, Ryan Varghese, Lalitha Shreya Vanam, Prabhath Adireddi, Peter Karkus, Nakul Gopalan
2026 Conference on Robot Learning (CoRL)
StageCraft: Execution Aware Mitigation of Distractor and Obstruction Failures in VLA Models
Kartikay Milind Pangaonkar, Prabin Rath, Omkar Patil, Nakul Gopalan
2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
PokeNet: Learning Kinematic Models of Articulated Objects from Human Observations
Anmol Gupta, Weiwei Gu, Omkar Patil, Jun Ki Lee, Nakul Gopalan
2026 IEEE International Conference on Robotics and Automation (ICRA)
Factorizing Diffusion Policies for Observation Modality Prioritization
Omkar Patil, Prabin Rath, Kartikay Pangaonkar, Eric Rosen, Nakul Gopalan
2026 IEEE International Conference on Robotics and Automation (ICRA)
XMoP- Whole-Body Control Policy for Zero-shot Cross-Embodiment Neural Motion Planning
Prabin Kumar Rath, Nakul Gopalan
2025 IEEE International Conference on Robotics and Automation (ICRA)
Learning Temporally Composable Task Segmentations with Language
Divyanshu Raj, Omkar Patil, Weiwei Gu, Chitta Baral, Nakul Gopalan
2024 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
Hardware-Software Co-Design for Path Planning by Drones
Ayushi Dube, Omkar Patil, Gian Singh, Nakul Gopalan, Sarma Vrudhula
2024 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
Interactive Visual Task Learning for Robots
Weiwei Gu, Anant Sah, Nakul Gopalan
In Proceedings of The 38th Annual AAAI Conference on Artificial Intelligence